Moon Rovers in the Fast Lane
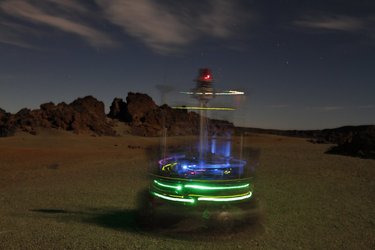
Future lunar rovers may need to do much more than cautiously inch their way across the Moon. They will need to travel longer distances, reach more science targets and operate in some of the most challenging environments ever explored. GMV UK and the UK Space Agency, through ESA's General Support Technology Programme (GSTP), have developed a new autonomous Guidance, Navigation and Control software helping make that vision a reality. FASTNAV aims to get rovers travelling across the lunar landscape at 1 metre per second – roughly 3.6km/h. Previously most rovers have only been able to crawl along at 0.2km/h. Shown here are field tests being undertaken in Bardenas Reales,, Spain, where the system is used to navigate volcanic terrain simulating the lunar surface to see how it fares. During the campaign, GMV carried out tests inspired by mission scenarios, including crater exploration and travel in low-visibility conditions simulating the permanently shadowed regions.